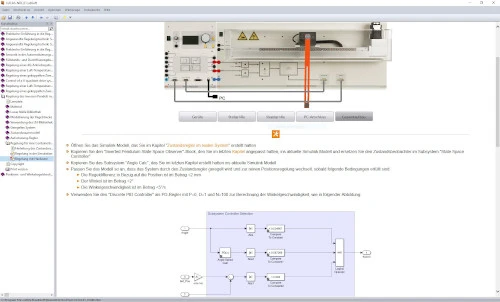



Closed Loop Control of a Position and Angle Control System Using Matlab Simulink
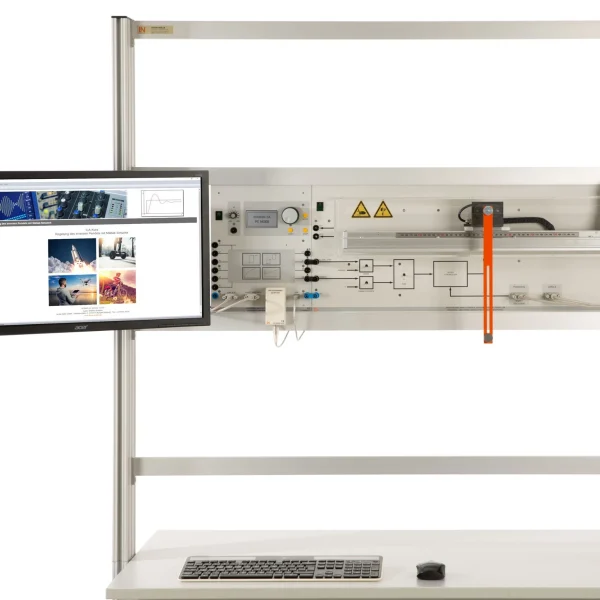
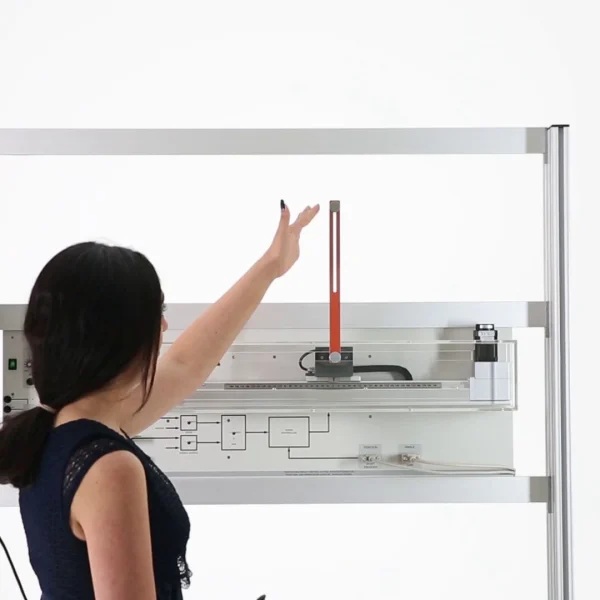
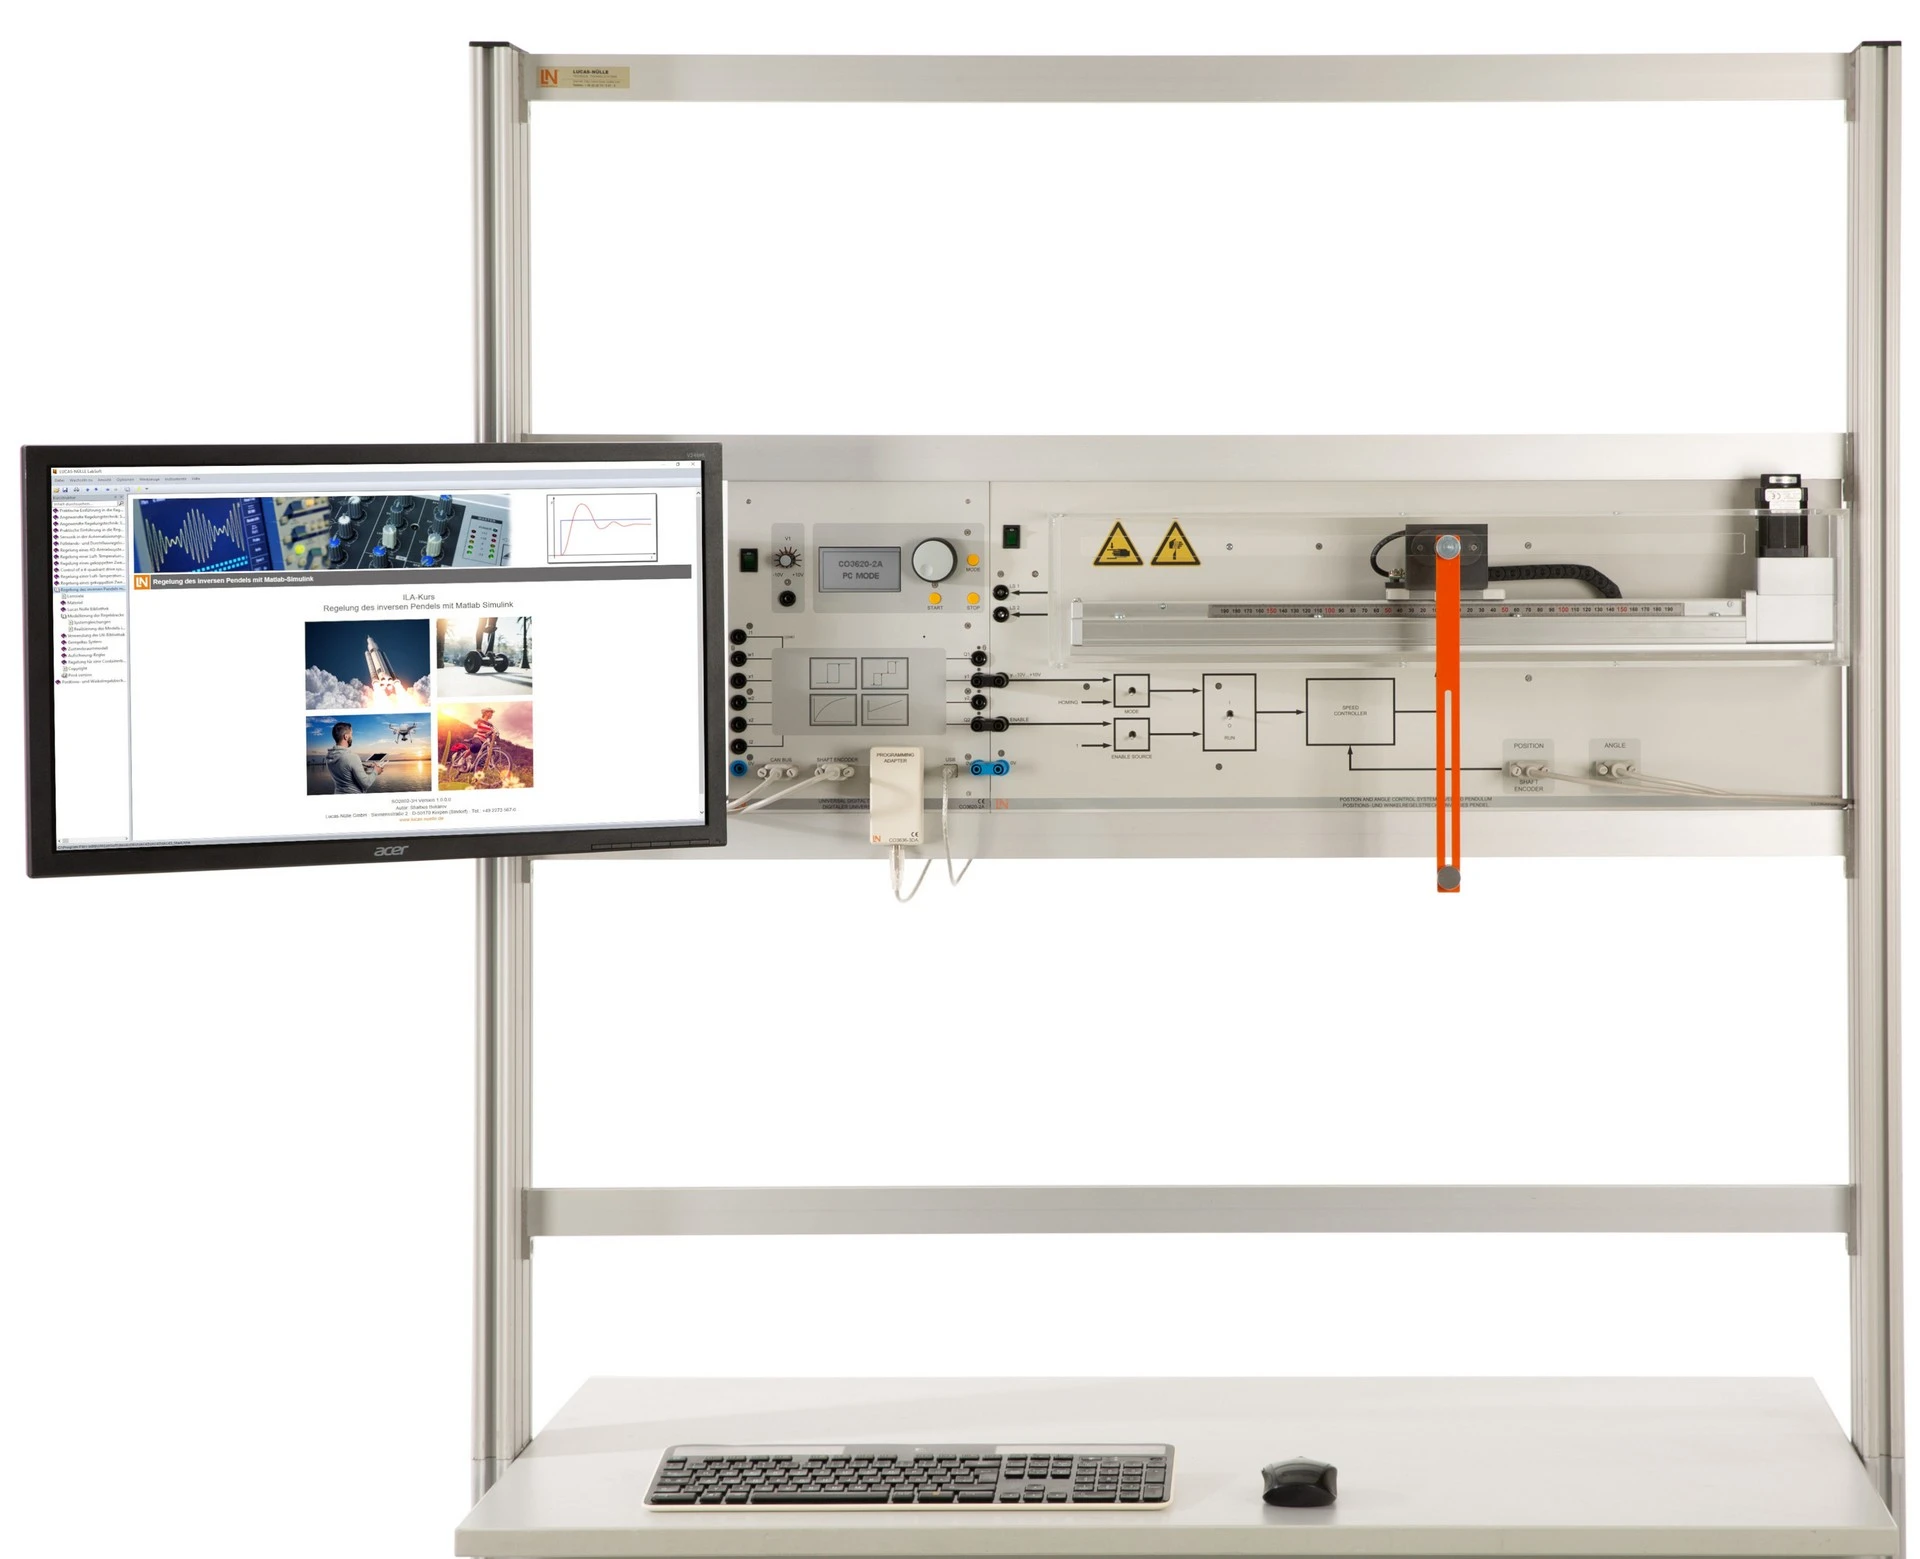
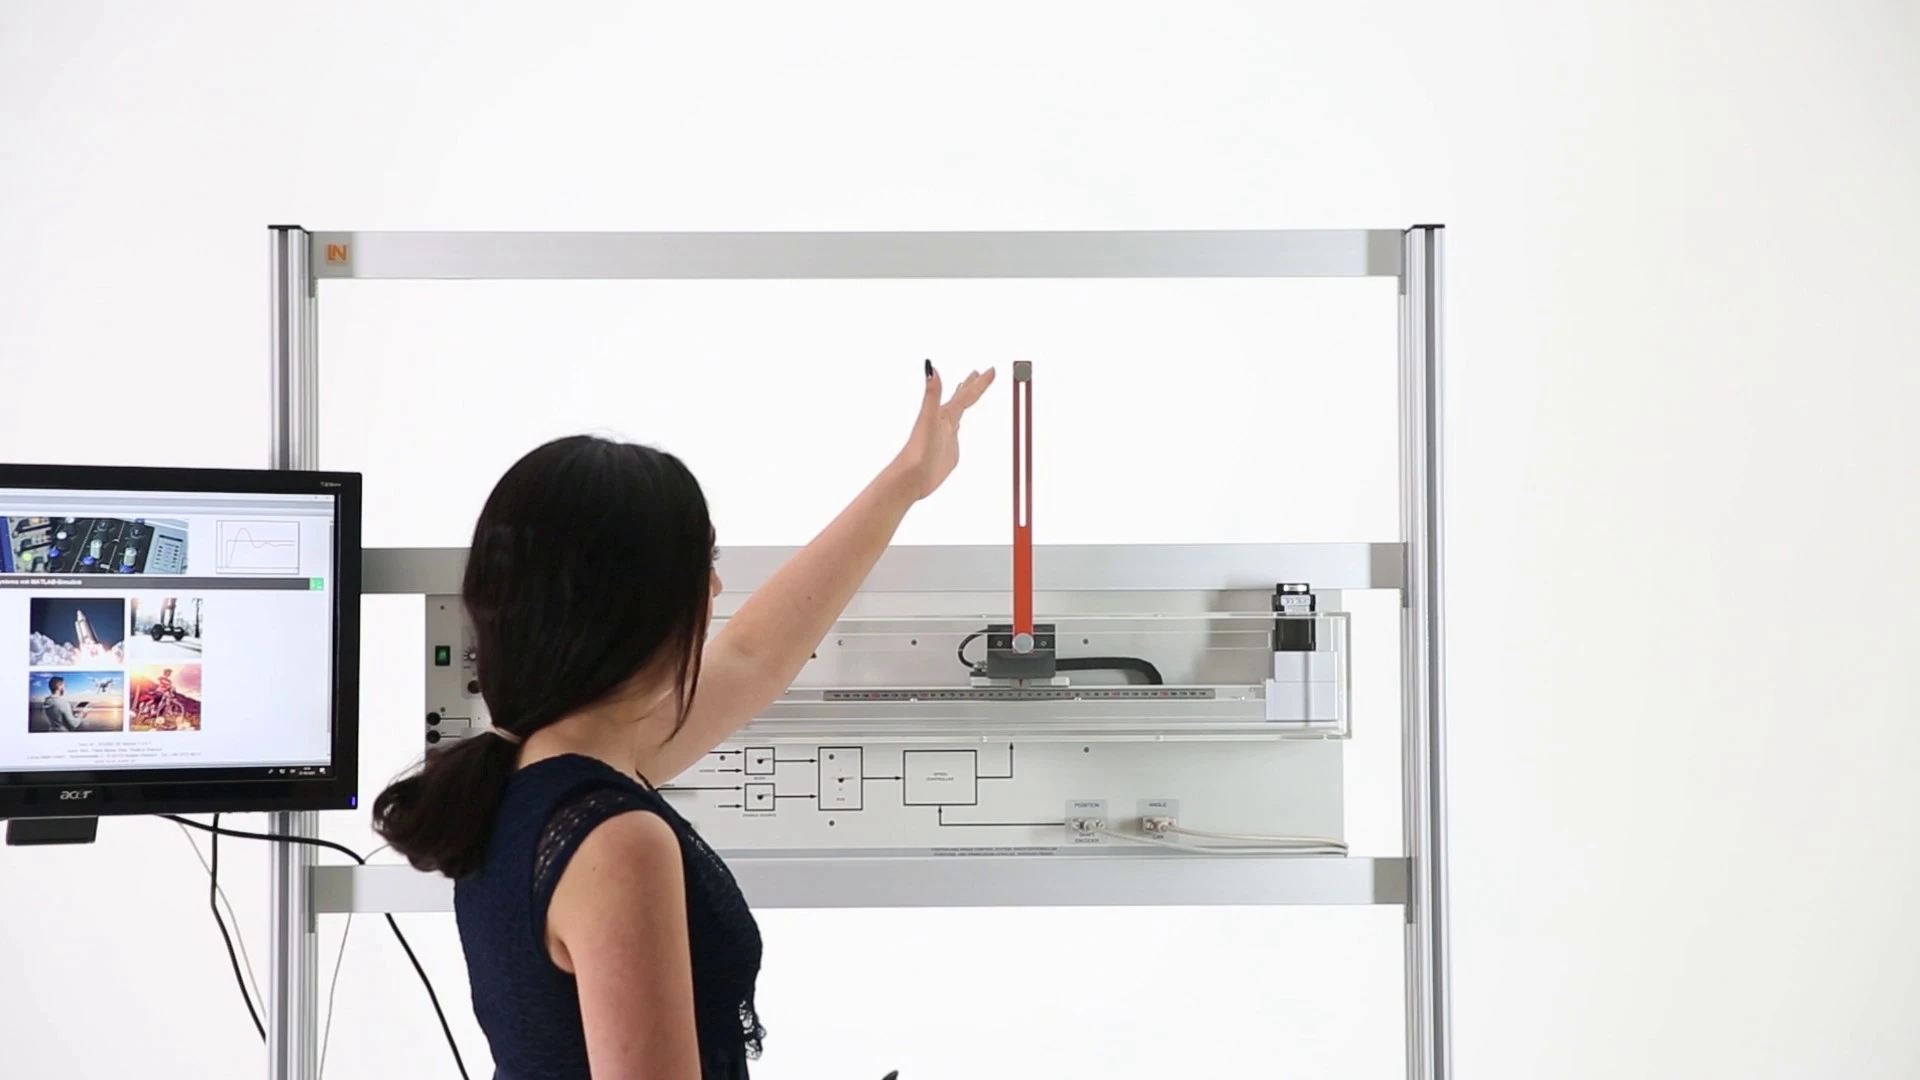
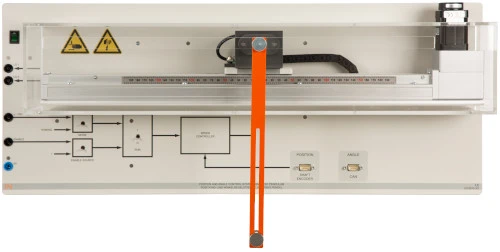
Training system consisting of a belt-driven linear axis and a pivoting pendulum rod. Students model the unstable system in state space and control it in real time directly from MATLAB/Simulink.
- Developing the model
- Designing a state-space model
- Optimizing PID control
- Implementing a state observer
- A classic control engineering application
- Seamless MATLAB integration
- HIL real-time control
- Variable pendulum center of gravity
Cranes, Segways and rockets have to be kept in unstable equilibrium, and this requires fast, precise control algorithms. The inverted pendulum is the classic model of this task: a pendulum rod pivots on a carriage that a belt drive moves over a distance of up to 400 mm. A CAN angle sensor with 16,000 pulses per revolution feeds back the deflection. Students derive the system equations, linearize them in state space and transfer their Simulink design to the hardware at the push of a button. There they optimize the parameters on the running system. By the end, they are able to swing the pendulum up from its lower rest position and damp the load swing of a simulated container crane.
| Base Product | |
| CO3620-2G | Position and Angle Control System, Inverted Pendulum |
| CO3636-3D | USB adapter with MATLAB toolbox for power electronics and process control |
| Course | |
| SO2802-3G | Interactive Lab Assistant: Control of a position and angle control system |
| SO2802-3H | Interactive Lab Assistant: Control of a position and angle control system using Matlab Simulink |
| Accessories | |
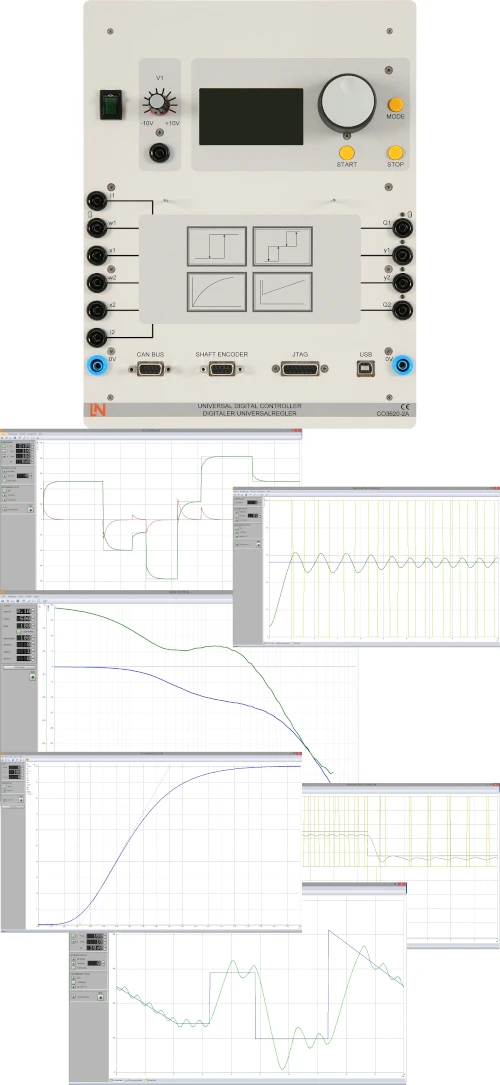
| CO3620-2A | Universal digital controller (DSP) |
| Furniture | |
| ST7200-7A | SybaPro experiment trolley, 3-level, 6 sockets, 1250x1970x800mm |
| ST8010-4T | Monitor holder for flat screen monitor of weight up to 15kg / 33lbs |
| ST7200-5L | Protection cover for three-level experiment trolleys |
| ST8010-4G | Keyboard adapter for flat screen monitor holders |
| ST8008-8N | Protected power distribution for working stations |
| ST8010-4J | Multiple socket outlet, 6 fold, with illuminated switch |
| Furniture Accessories | |
| ST8000-6A | Display for the Control Technology equipment |
| Measurement Leads | |
| SO5148-1V | Set of safety measurement cables, 4mm (20 leads) |
| SO5126-3R | Safety connecting plug 4mm with tap (2x), black, 1000V/32A CAT II |
| SO5126-3V | Safety connecting plug 4mm with tap (2x), blue, 1000V/32A CAT II |
Learning Content in Detail
Developing the model
Designing a state-space model
Optimizing PID control
Implementing a state observer
Developing a swing-up controller
Simulating a real-world application
Features & Applications
- A classic control engineering application — Students investigate the inverted pendulum as a classic control engineering problem and learn how to stabilize an unstable system.
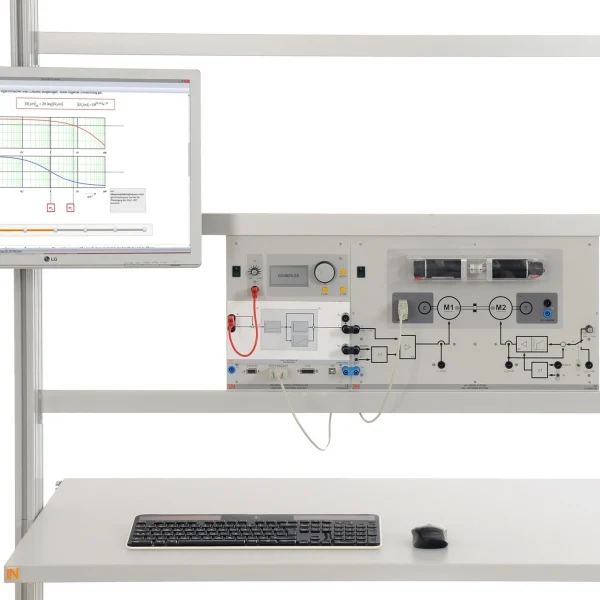
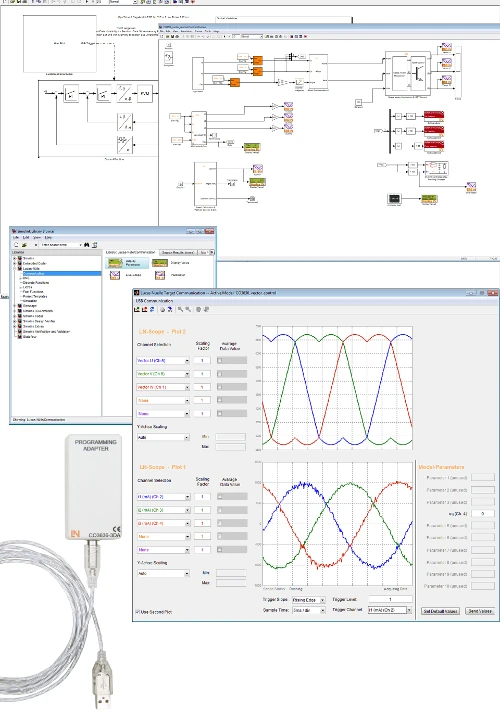
- Seamless MATLAB integration — Simulink models are transferred directly to the hardware. The code is compiled in real time, with no need to switch between systems.
- HIL real-time control — Students test their control algorithms as hardware-in-the-loop and optimize the parameters on the running system.
- Variable pendulum center of gravity — The pendulum’s center of gravity can be shifted. This allows students to change the properties of the controlled system and check how robust their control remains.
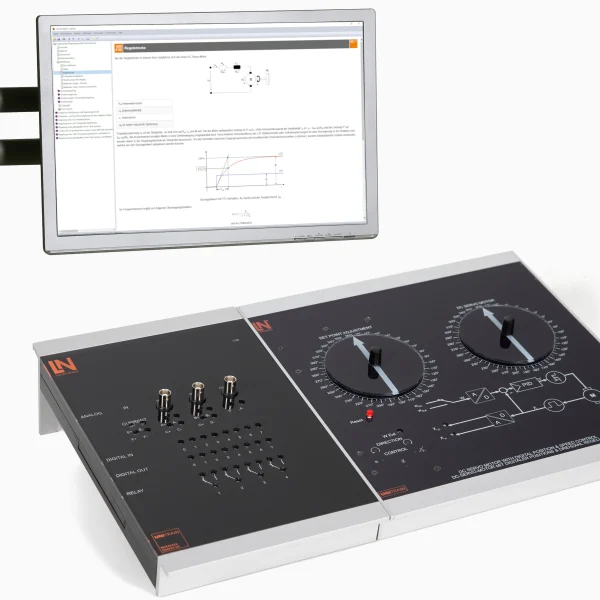
- LN toolbox with JTAG programming adapter — Models and algorithms are created in MATLAB Simulink and transferred to the hardware at the push of a button.
- Belt drive with recirculating ball guide — The guide allows precise, low-friction linear movements over a travel distance of up to 400 mm.
- Hybrid stepper motor with up to 100 W — Current and speed control are integrated, enabling highly dynamic motion profiles.
- CAN angle sensor — The high-resolution incremental encoder delivers 16,000 pulses per revolution via a CAN interface.
- LN toolbox for MATLAB Simulink — The library provides ready-made hardware blocks and reduces the time needed to build models in Simulink.
- Integrated live scope — Students visualize system variables in real time and make changes while the system is running.

From Knowledge Comes Capability.
You guide the learning
Where theory and practice go hand in hand.
RXLea brings a new way of learning: project-based, hands-on and clearly structured. Learners solve real-world tasks, while instructors save time on preparation. Interactive modules, smart analytics and real hardware create a modern, efficient learning world.
Hands-on and interactive
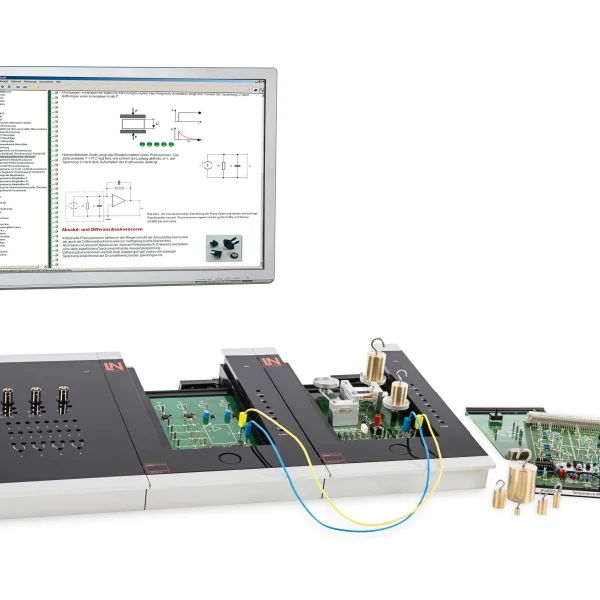
Animations, interactive tasks and realistic scenarios build a deep understanding. All content is organized into clear learning paths for focused, hands-on learning.
Digital support
3D assembly animations and digital instructions simplify complex procedures, reduce errors and help learners work more independently.
Visual support
Overview graphics, screenshots and sample animations make the learning world transparent. Photos from the learning packages are also available, including country-specific versions where needed.




Stay ahead in
technical training.
Get the latest training systems, product launches and educational insights, delivered directly to your inbox.